Zhilun Hu
Ph.D. student · Huazhong University of Science and Technology
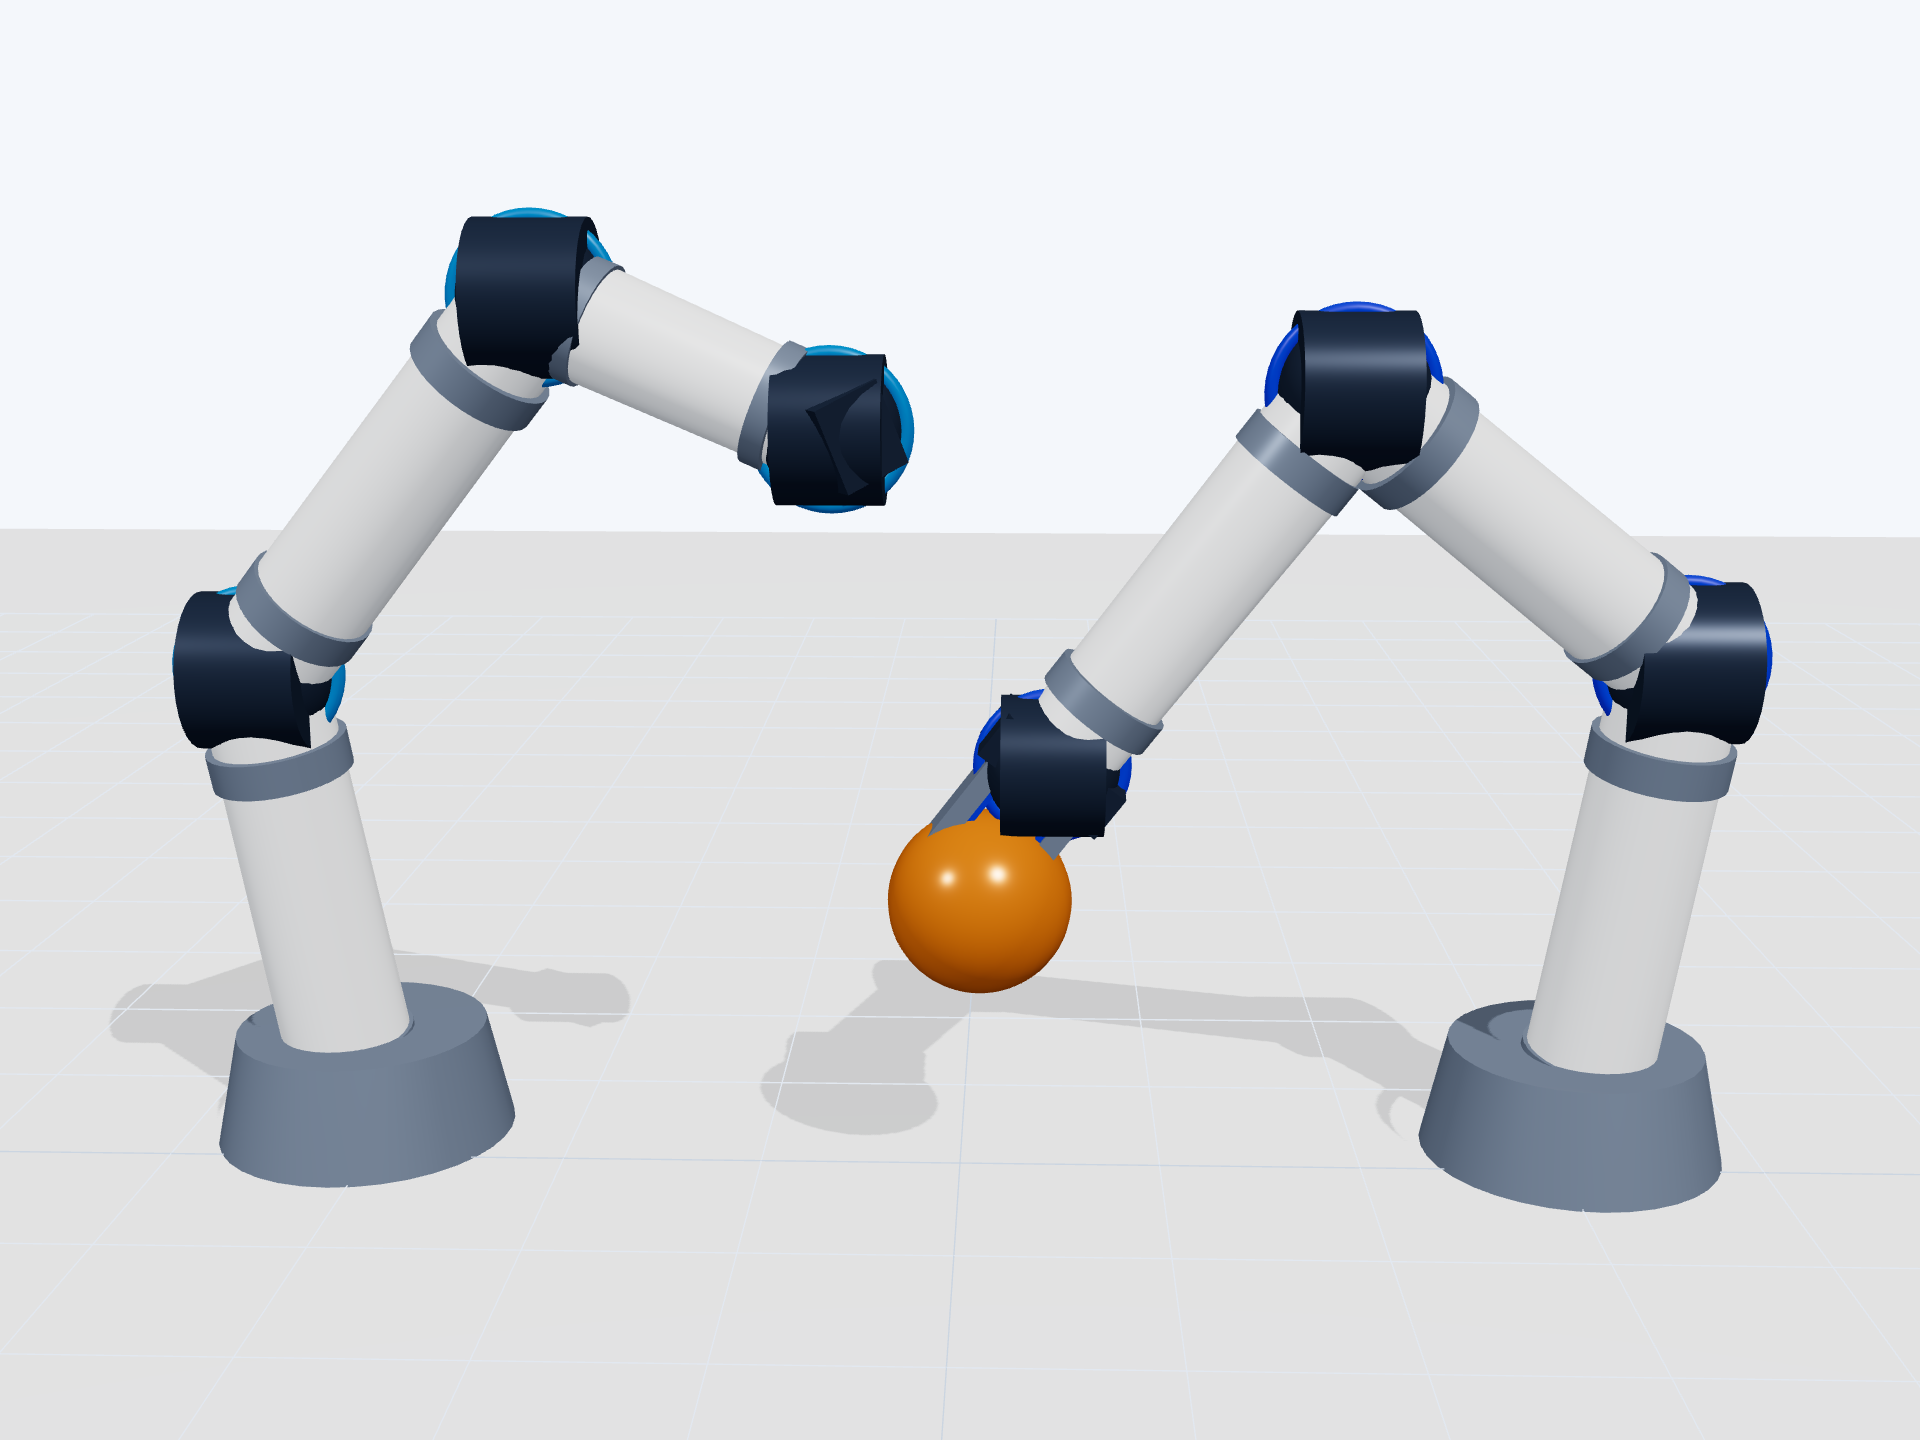
I am Zhilun Hu (胡至伦), a Ph.D. student in the School of Mechanical Science and Engineering at Huazhong University of Science and Technology (HUST), advised by Prof. Weiming Shen (IEEE Fellow, Academician of CAE).
My research centers on reliable robotic manipulation: investigating how physical agents actively acquire unoccluded visual observations, verify high-level action proposals against geometric constraints prior to execution, and adapt contact-rich manipulation policies through visuotactile interaction.
我是胡至伦,华中科技大学机械科学与工程学院博士研究生,师从沈卫明教授。我的研究致力于解决机器人操作中的可靠性问题(Reliable Robotic Manipulation),构建涵盖主动视觉伺服感知、双臂柔性操作先验视觉校验与视触觉多模态强化学习控制的闭环操作体系。
🌐 Switch to Bilingual Full-Width Edition (切换至双栏中英旗舰版主页 hzl666.top) →
Closed-Loop Manipulation Architecture
- 01 · Active Perception (
Active Observation) — Coordinating an active eye-in-hand RGB-D camera arm with target–gripper relative visual servoing to preserve co-visibility under occlusion. - 02 · Pre-Execution Verification (
VR-Loop) — Iterative Vision-Language action critique via visual-overlay rendering, mask constraints, and depth-informed 3D geometry for dual-arm rope untangling. - 03 · Visuotactile Learning & Closed-Loop Recovery — Cross-modal fusion of vision and tactile force fields with reinforcement learning for contact-rich manipulation and closed-loop execution recovery.
Representative Research & Visual Overview
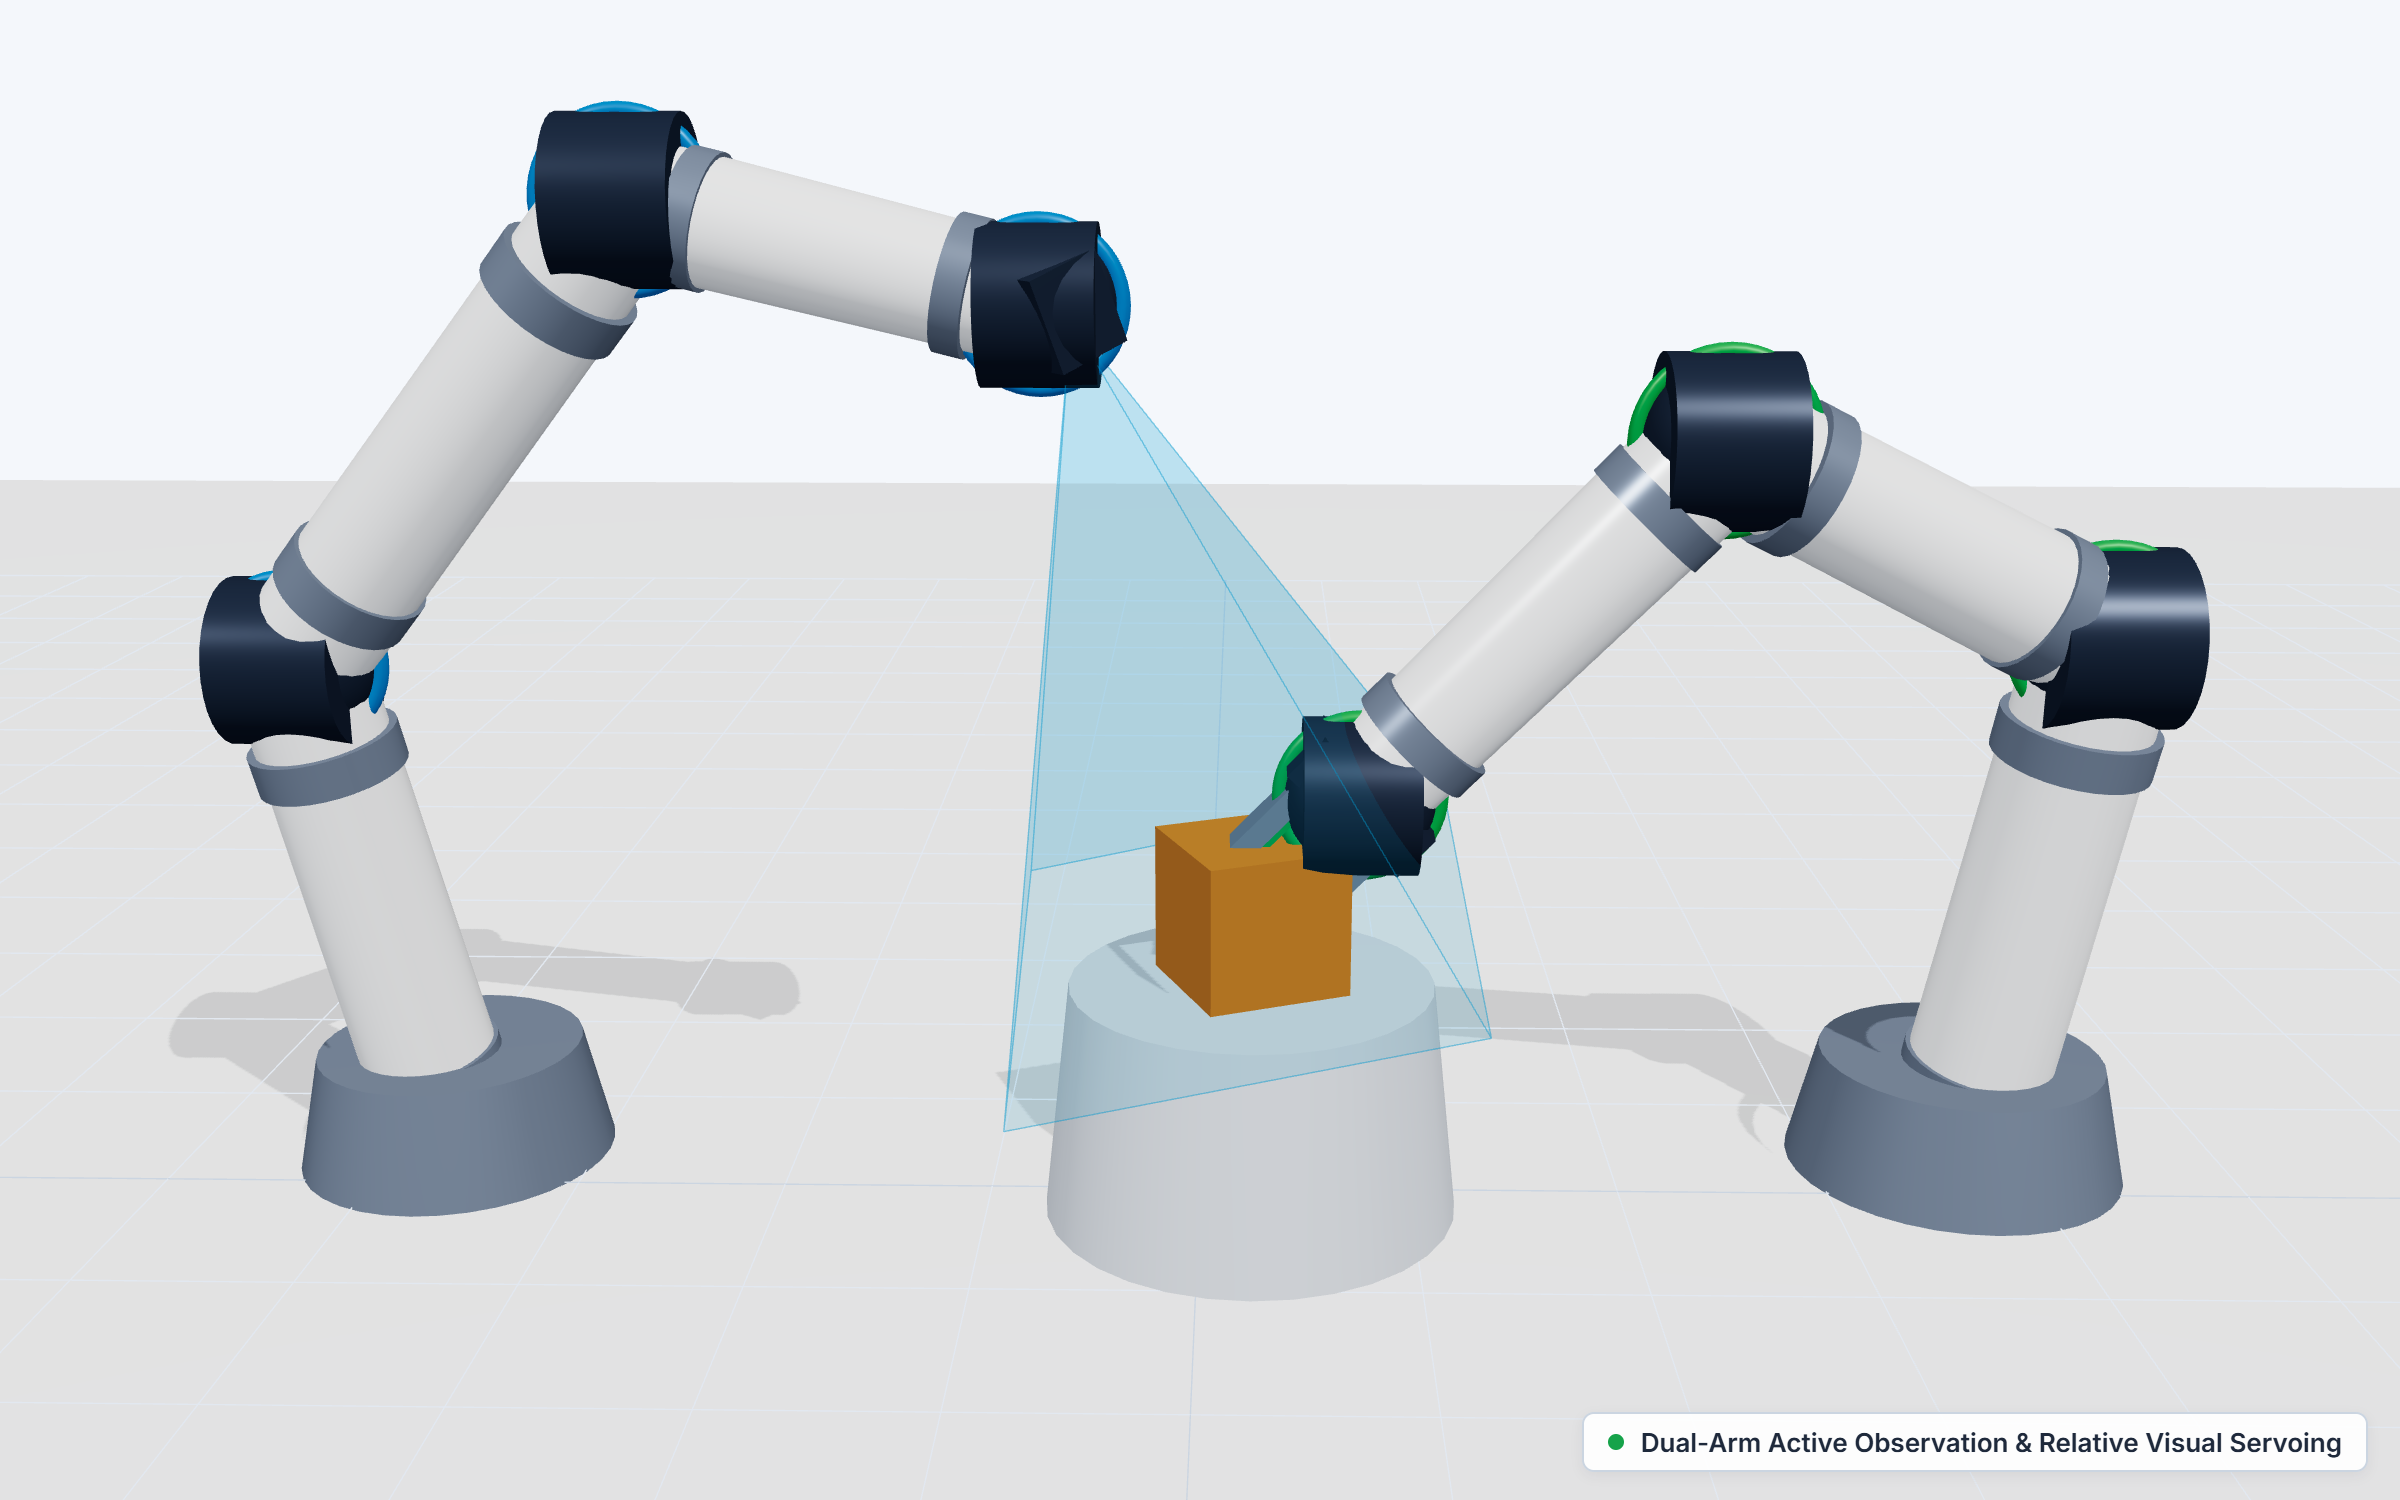
Active Observation for Robust Visual Servoing in Robotic Manipulation
Zhilun Hu, Yuqi Cheng, Yuxiang Tan, Wen-pan Li, Weiming Shen.
IEEE CASE 2026 · Accepted (Session ThCT6.3) · First Author
During terminal grasping, the manipulator or gripper frequently obscures the target object just when closed-loop visual feedback is most critical. This work uses an active camera arm coupled with target–gripper relative visual servoing and occlusion-triggered viewpoint exploration to maintain or recover clear visual feedback.
Official Program (ThCT6.3) · Project Page
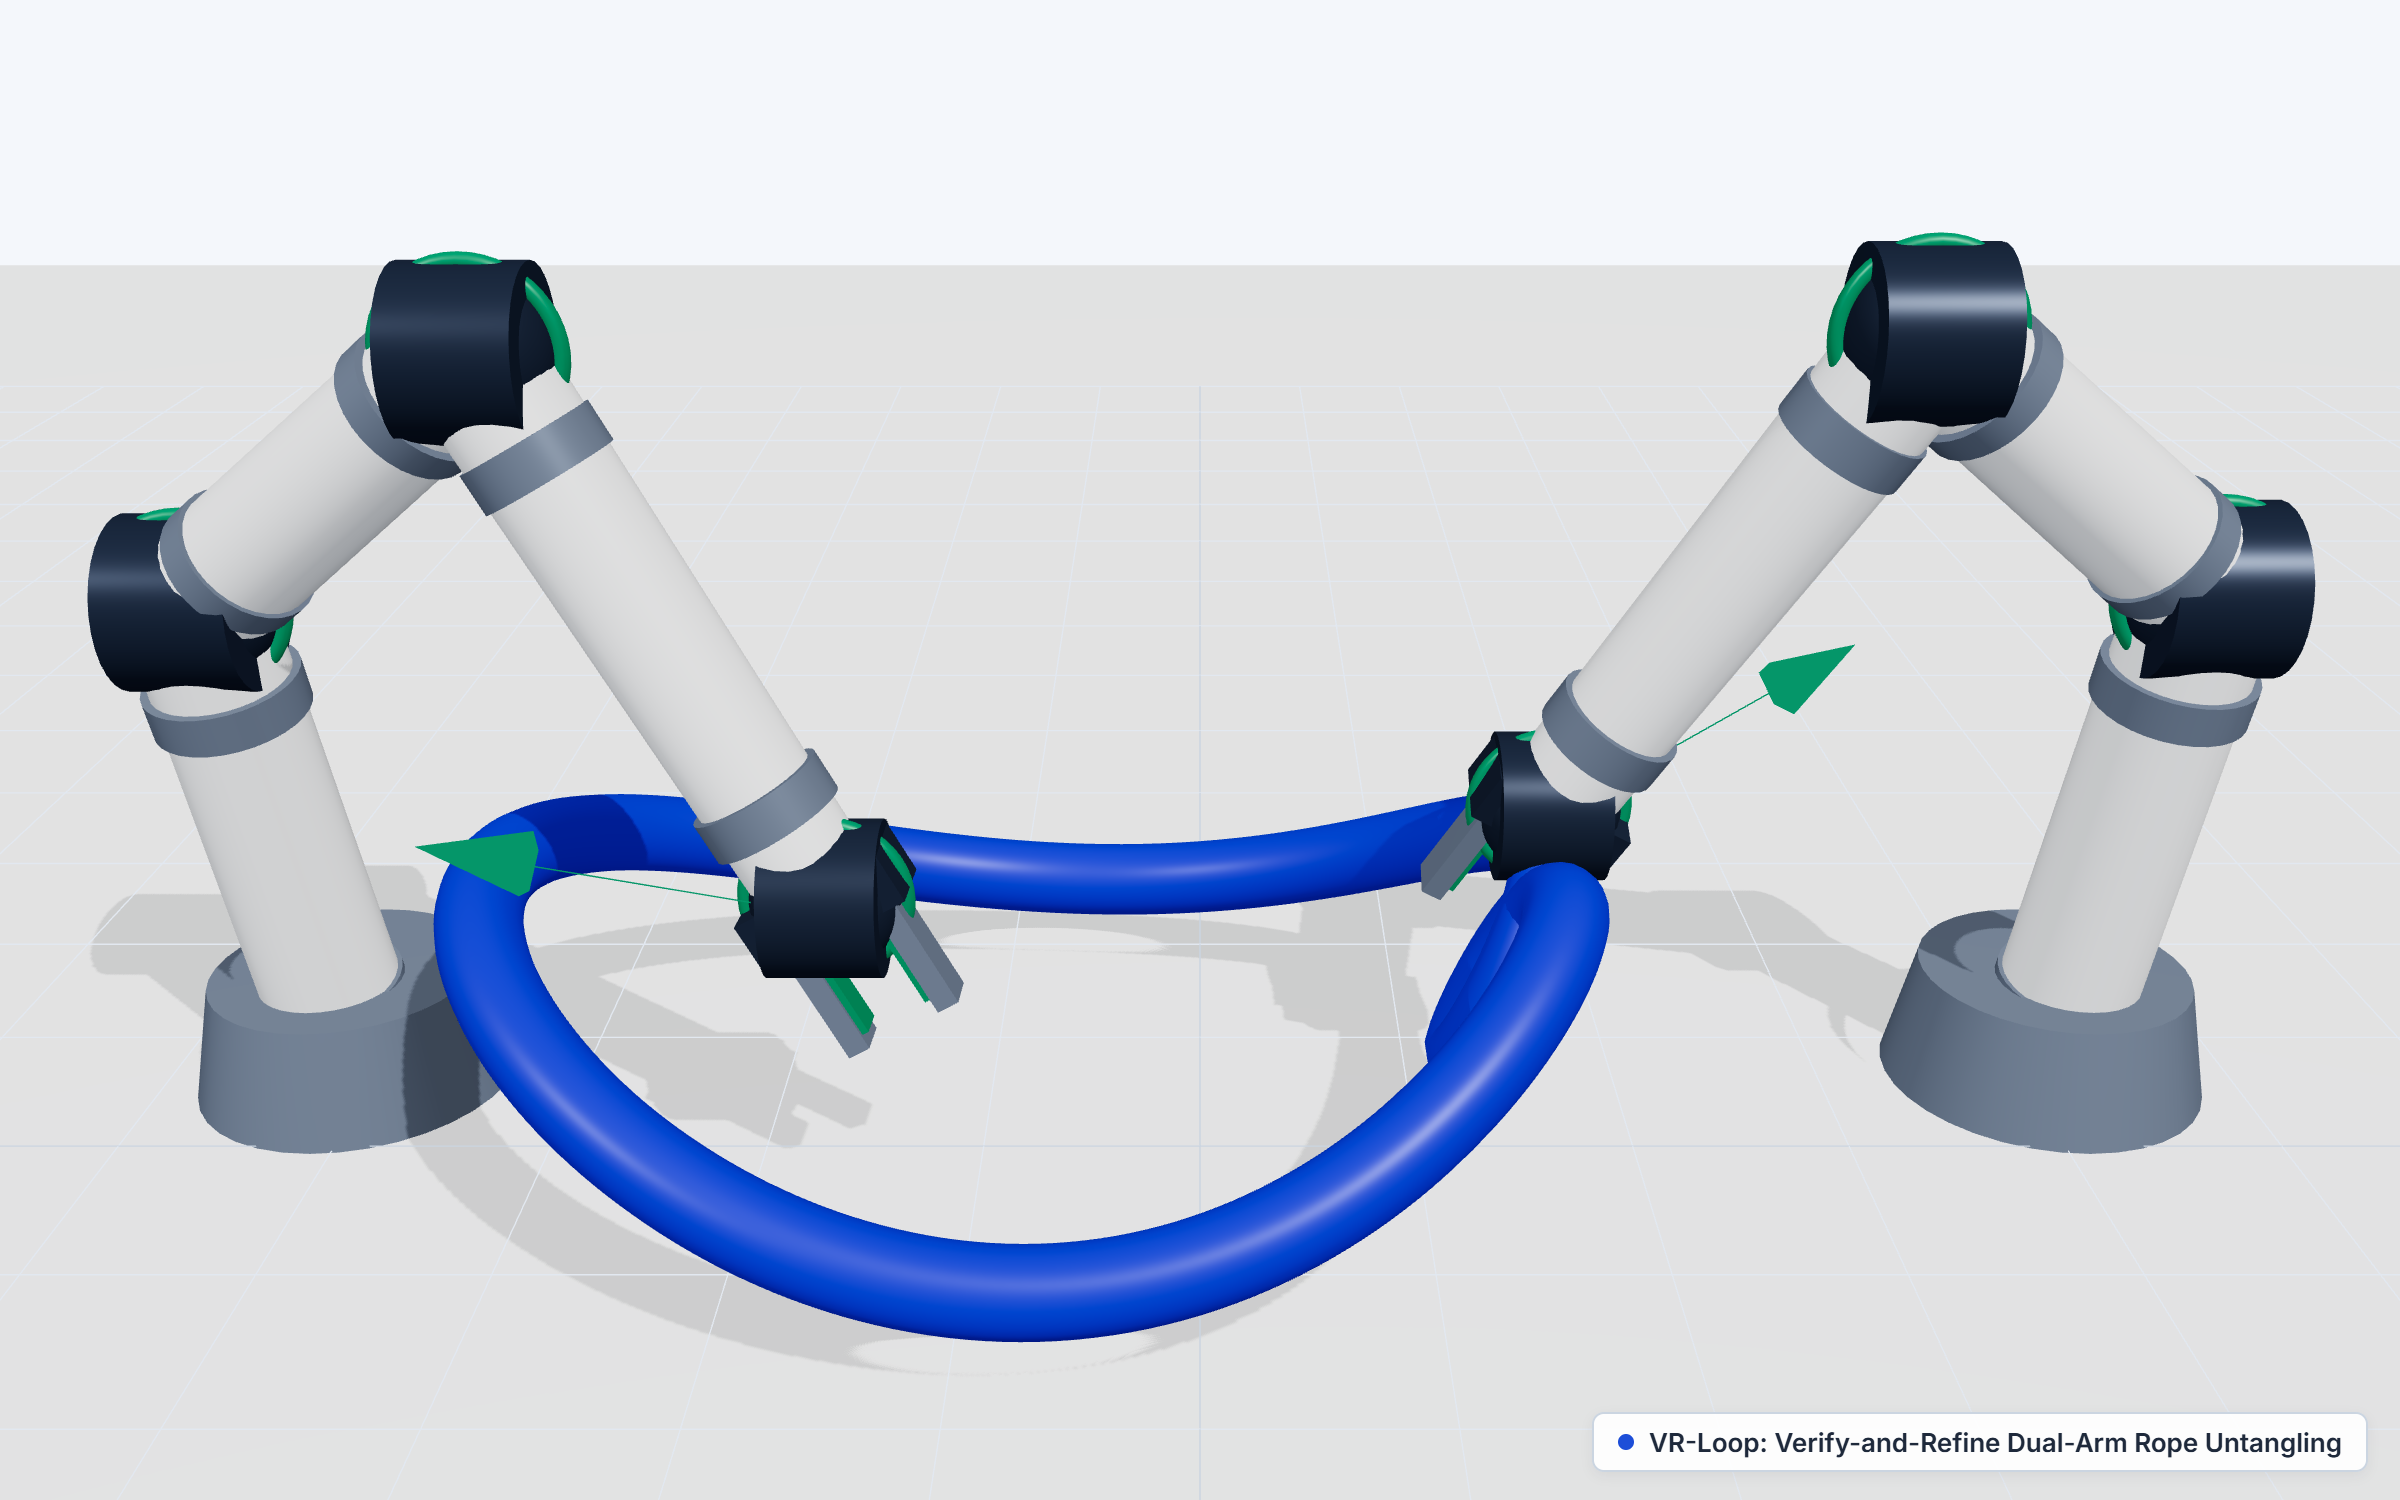
Iterative Verify-and-Refine Vision-Language Agent for Reliable Dual-Arm Manipulation
Yuqi Cheng, Zhilun Hu, Cheng Jiang, Qingyu Peng, Weiming Shen.
Manuscript Under Review · Second Author
In deformable rope untangling, an unverified grasp or pull can irreversibly tighten a knot. VR-Loop renders candidate dual-arm actions onto image overlays, critiques crossing topology and mask constraints prior to execution, and synthesizes collision-free 3D trajectories.
Project Page · All Publications · Curriculum Vitae · ORCID · GitHub